About Me
Hi! I'm Songqi, also known as Carson. I am currently an Algorithm Engineer at XGRIDS, working on Agent research and development, general perception, VLM post-training, 3D reconstruction, and point cloud completion. I received my master's degree from the Ocean University of China, where I was advised by Prof. Cai Qing at VMV Lab.
你好,我是孔松琦。目前在 XGRIDS 担任算法工程师,从事 Agent 研究与开发、通用感知、VLM 后训练、三维重建与点云补全。硕士毕业于中国海洋大学,师从蔡青教授,就读于 VMV Lab。
During my master's studies, my research interests centered on 3D vision, point cloud completion, and 3D reconstruction from uncalibrated single views.
攻读硕士期间,研究兴趣集中在三维视觉、点云补全,以及非标定单视图下的三维重建。
Work Experience
 XGRIDS
3D vision, LiDAR point clouds, and 3D reconstruction from uncalibrated scenarios.
三维视觉、激光雷达点云,以及非标定场景下的三维重建。
 DeepRoute.AI
Autonomous driving perception, working on LiDAR-based detection and segmentation.
自动驾驶感知,从事基于激光雷达的检测与分割。
 Tencent Cloud
Cloud architecture design and engineering practice.
云计算架构设计与工程实践。
Publications
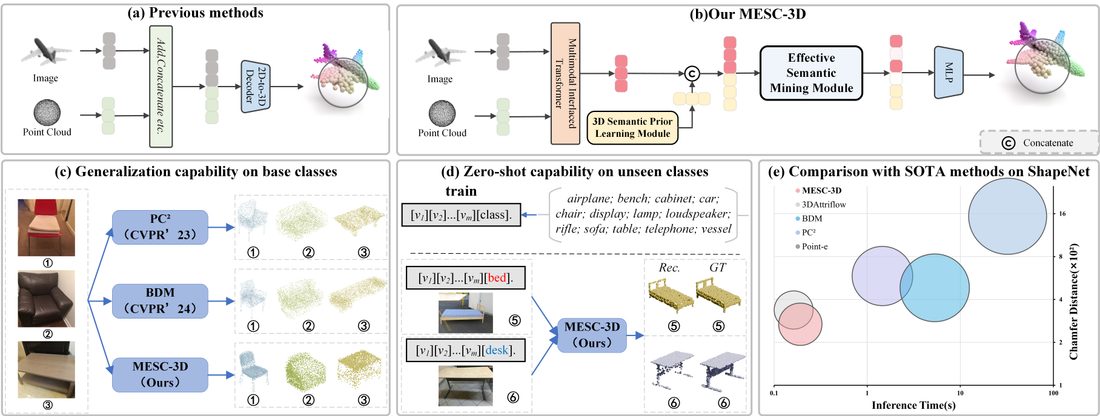
Existing methods simply concatenate image semantics with 3D point clouds, and the entangled features hold back reconstruction. MESC-3D actively mines effective semantic cues through an Effective Semantic Mining Module, and adds a 3D Semantic Prior Learning Module with learnable text prompts to compensate for occlusions…
已有方法多把图像语义与三维点云直接拼接,纠缠的特征会限制重建质量。MESC-3D 通过有效语义挖掘模块主动筛选语义线索,并引入带可学习文本提示的三维语义先验学习模块,弥补遮挡造成的信息缺失……
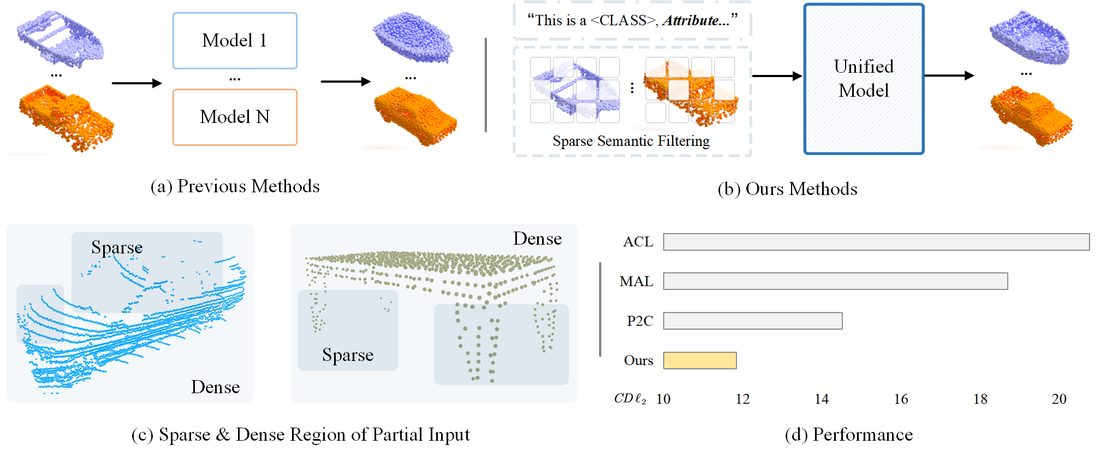
Self-supervised point cloud completion predicts missing structure without paired data, yet random sampling discards critical semantic details and class-wise models do not scale. SMSPC preserves key regions with a Gumbel Top-k sparse semantic filtering module, trains one unified model across categories, and aligns predicted features with class-specific text prompts…
自监督点云补全无需成对数据即可预测缺失结构,但随机采样容易丢失关键语义,逐类别训练也难以扩展。SMSPC 用基于 Gumbel Top-k 的稀疏语义过滤模块保留关键区域,以统一模型覆盖多个类别,并将预测语义特征与类别文本提示对齐……
 Ocean University of China
 Qingdao University of Technology